Description
Key Technical Specifications
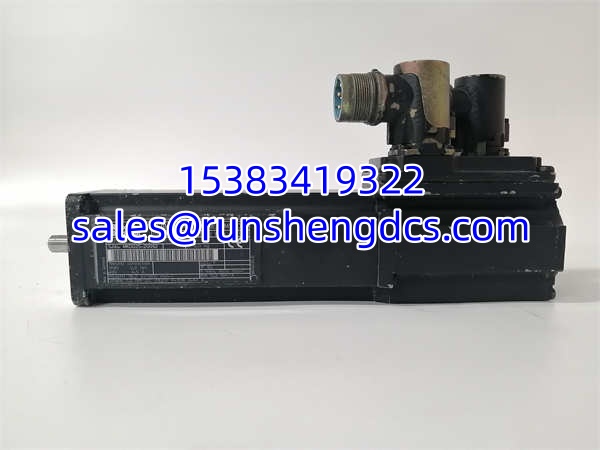
- Product Model: MKD025B-144-KG1-UN
- Brand: Bosch Rexroth / Indramat
- Product Type: Synchronous servo motor
- Series: IndraDyn M / MKD
- Rated Power: Approx. 0.63 kW
- Rated Torque: 2.0 Nm
- Peak Torque: 6.0 Nm
- Rated Speed: 3000 rpm
- Maximum Speed: 6000 rpm
- Stator Voltage: 230 V AC, 3-phase
- Encoder: KG1 typically indicates 1024-line incremental encoder
- Cooling: Self-cooled / natural cooling
- Protection Class: IP65 at shaft end / IP54 housing, typical for MKD025B variants
- Mounting: B5 flange, standard for this family
- Shaft: Keyed shaft; brake status depends on full suffix
Product Introduction
On a machine tool or automation line, this is the kind of motor that shows up where positioning speed, repeatability, and fast acceleration matter. The MKD025B-144-KG1-UN belongs to the Rexroth IndraDyn M family, not a general-purpose AC motor or VFD-driven conveyor motor. It is built for closed-loop servo control, short move cycles, frequent starts/stops, and tight position or speed regulation.
Its practical value is as a replacement servo motor for an existing Rexroth/Indramat motion system. If the encoder type, shaft configuration, mounting, brake option, and drive compatibility all match, it can restore axis motion without redesigning the machine. If the suffix is wrong, the motor may physically fit but still fail to tune, commutate, or report position correctly.
Troubleshooting Quick Reference
| Fault | Likely Cause | Quick Check | Fix |
|---|---|---|---|
| Motor does not rotate | Drive fault, enable missing, or motor cable open | Check drive alarms; measure U/V/W at motor plug | Verify enable, brake release, and motor cable continuity |
| Drive reports encoder fault | Wrong encoder type, damaged cable, or bad connector | Check A/B/Z signals and 5 V supply | Inspect encoder cable, shielding, and connector pins |
| Excessive vibration or noise | Mechanical coupling, bearing wear, or poor tuning | Run motor uncoupled if safe | Check coupling, bearings, load inertia, and tuning |
| Overtemperature | Overload, blocked cooling, or high ambient | Measure motor surface temp; check duty cycle | Reduce load, improve airflow, verify torque settings |
| Position drift | Encoder feedback loss or loose coupling | Monitor position counter during motion | Tighten encoder coupling; check shielding and grounding |
| Motor hums but stalls | Phase loss, wrong motor data, or drive mismatch | Measure 3-phase output; confirm motor nameplate data | Check U/V/W wiring; verify motor parameter set in drive |
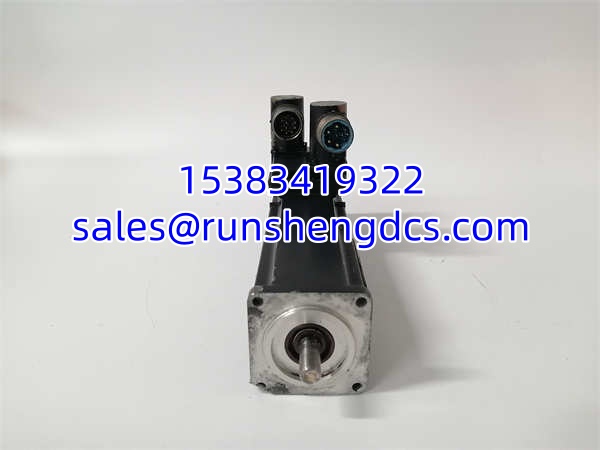
Rexroth MKD025B-144-KG1-UN
Application Scenarios & Pain Points
- Machine tool feed axes: Needs precise positioning and fast response. Pain point: wrong encoder suffix causes tuning failures or position errors.
- Automation indexing: Short moves, frequent stops. Pain point: peak torque and inertia mismatch can cause missed positions or long settle times.
- Robotics or handling systems: Compact motor with high dynamic response. Pain point: shaft key, flange, or cable entry orientation may not match the original installation.
- Legacy Indramat/Rexroth machines: Older servo systems often run with aging cables and connectors. Pain point: a “new” surplus motor may be fine, but the cable or drive parameter set is the real fault.
- Emergency spare procurement: Buyers often search only for MKD025B-144. Pain point: KG1 vs KG0, UN vs KN, and brake/shaft options are easy to miss.