Description
Key Technical Specifications
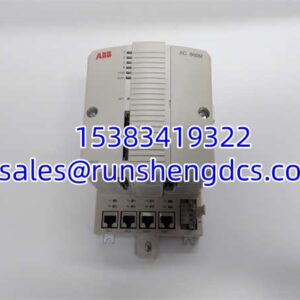
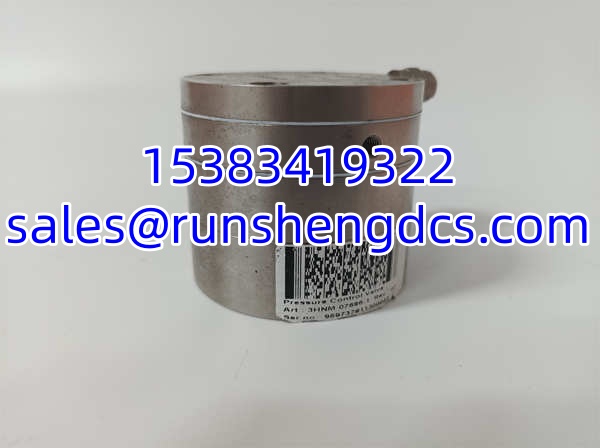
- Product Model: 3HNM07686-1
- Manufacturer: ABB
- System Platform: ABB IRC5 / S4C+ Robot Controllers
- Primary Function: Axis position and trajectory calculation
- Associated Module: 3HNM07485-1/07
- Processing: High-precision motion control algorithms
- Application: Industrial Robot Axis Control Systems
- Operating Temp: 0°C to +55°C (Verify cabinet cooling)
- Mounting: Standard IRC5 Rack Slot
- Diagnostics: Axis fault reporting, Position error logging
- Power: 24V DC (via backplane)
- Warranty: Typically 12 Months (Supplier Dependent)
Product Introduction
Robot stops mid-path with a “Axis Calculation Fault”? You’re looking at the 3HNM07686-1. This isn’t a generic I/O card. It’s the math engine for your robot’s movement. It calculates the exact position and trajectory for every axis, thousands of times per second. If this board drifts or lags, the robot jerks, alarms out, or worse—crashes into the fixture.
Why is it critical? Because it handles the kinematics that keep the tool center point (TCP) smooth. It works in tandem with the 3HNM07485-1/07 module to ensure coordinated motion. Without it, your robot is just a pile of expensive metal. Bottom line: it’s the brain behind the brawn. If you’re seeing trajectory errors or axis sync faults, this is your first suspect. Keep a spare if you run 24/7.
Troubleshooting Quick Reference
- Axis Calculation Fault / Trajectory Error: 85% chance of board failure or firmware mismatch. Check the LED status on the 3HNM07686-1. If it’s flashing a fault code, pull the board. Verify the firmware version matches the 3HNM07485-1/07 module. Mismatched revisions cause sync errors.
- Robot Jerky Motion / Poor Path Accuracy: 75% chance of calculation lag or noise. The 3HNM07686-1 needs clean power. Measure the 24V DC at the backplane. Ripple >100mV can corrupt trajectory math. Check the grounding strap on the board.
- Axis Won’t Home / Reference Fail: 70% chance of encoder feedback issue or calculation board. The 3HNM07686-1 processes the encoder data. If the encoder is good but the board won’t accept the reference, the input stage on the 3HNM07686-1 might be fried.
- Intermittent Alarms After Warm-up: 60% chance of thermal failure. The 3HNM07686-1 runs hot. Check the cabinet fan. If the board works cold but fails after 30 minutes, it’s a cracked solder joint or failing capacitor. Reseat the board firmly.
- Communication Loss with Main CPU: 50% chance of backplane connector issue. The 3HNM07686-1 plugs directly into the IRC5 rack. Inspect the pins for corrosion or bending. Reseat the module. Don’t force it.
ABB 3HNM07686-1
Application Scenarios & Pain Points
- High-Speed Pick & Place: Cycle times <1 second. Pain Point: Trajectory overshoot causing missed catches. Fix: The 3HNM07686-1 must be calculating at full speed. Verify the robot isn’t in “Low Speed” mode. Check for axis lag in the oscilloscope view. If the board is old, it might be struggling with complex paths.
- Arc Welding Cells: Continuous path accuracy. Pain Point: Seam wandering due to calculation drift. Fix: The 3HNM07686-1 handles the interpolation. If the weld is straight but the robot path is wavy, check the 3HNM07485-1/07 servo loop. If the path is mathematically wrong, the 3HNM07686-1 is suspect.
- Legacy S4C+ Retrofits: Running old robots on new lines. Pain Point: Finding spares for 3HNM07686-1. Fix: These are aging. Test your spare before the line goes down. The 3HNM07686-1 is not cheap. Verify the 3HNM07485-1/07 is also healthy; they age together.